Engineering & Product Development
Autonomous Desktop Explorer Robot
May 2026
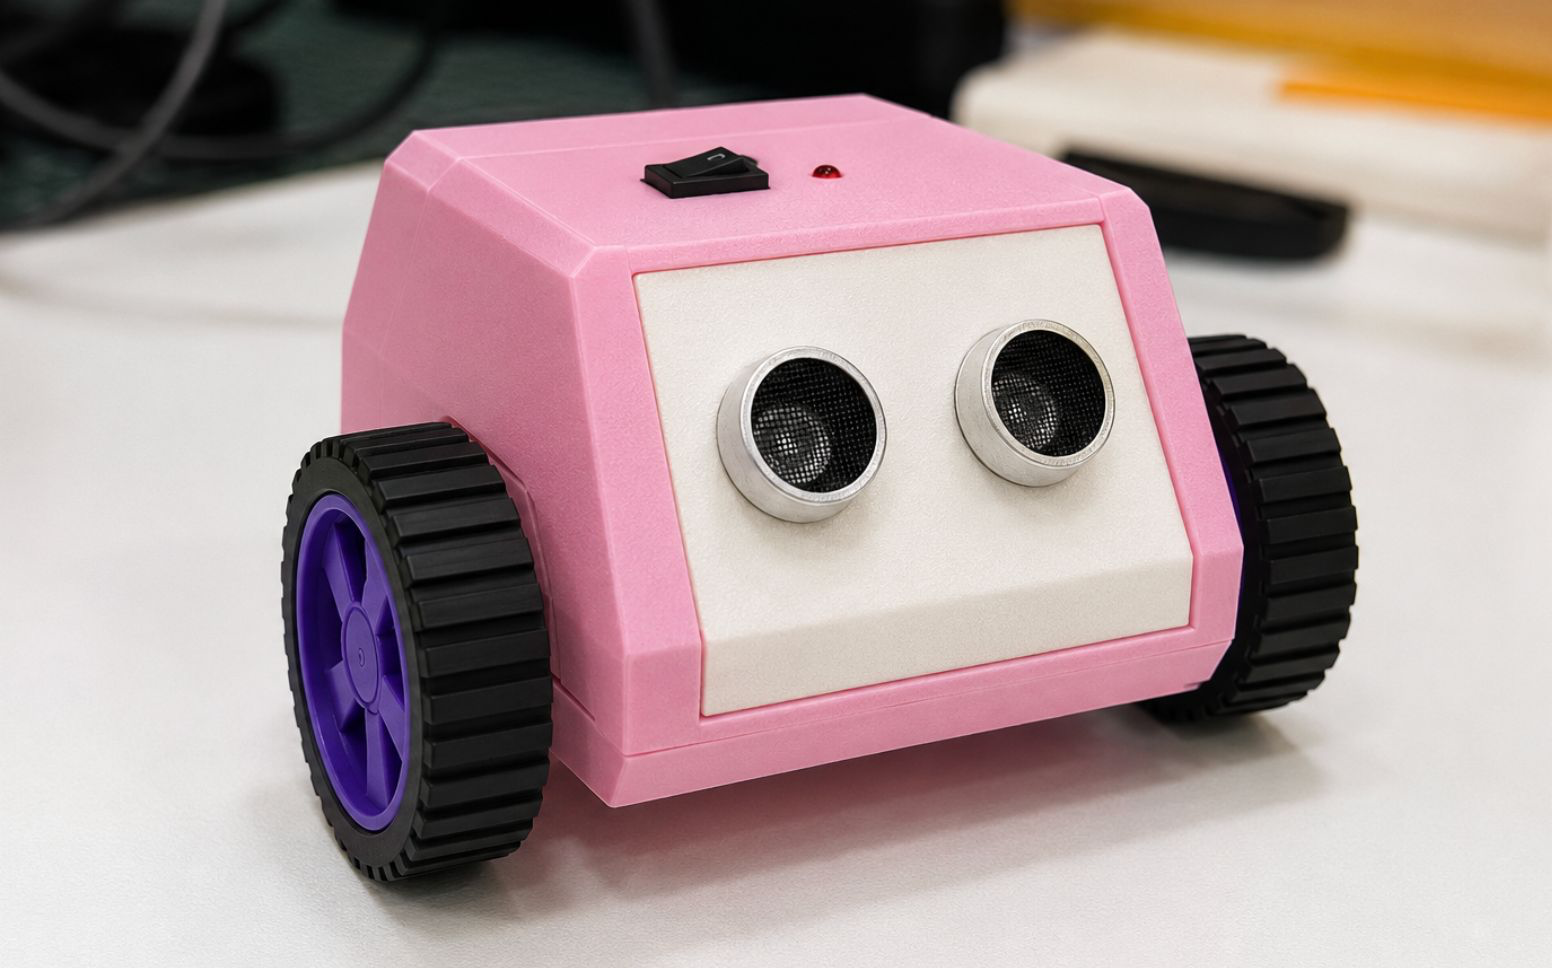
Compact obstacle-avoiding desktop robot, designed from scratch
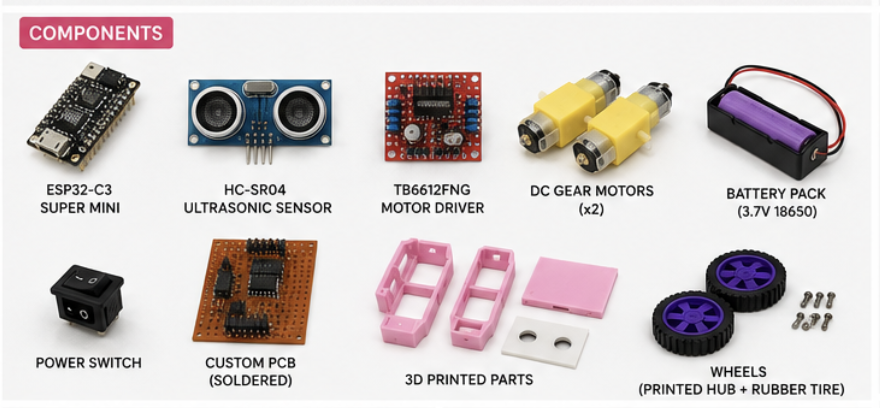
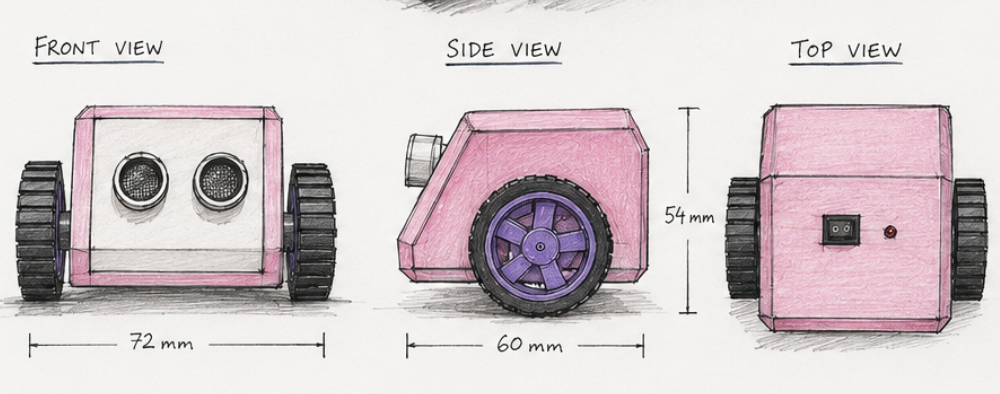
I designed and built a compact autonomous desktop robot that can detect nearby obstacles and navigate around them without manual control. The project began as a small personal build, but I treated it as a complete product-design exercise rather than simply assembling electronics onto an exposed chassis. The mechanical structure was designed from scratch in Fusion 360. One of my main goals was creating a clean, modular assembly without screws or permanent adhesives, so I developed snap-fit joints and friction-fit connections between the chassis panels. I also added a rear battery carriage to hold two LiPo batteries, improving portability while balancing the robot’s weight over the drive wheels. The ultrasonic sensor was integrated into a custom faceplate, giving the robot its distinctive “eyes” while keeping the sensor aligned parallel to the desk surface. For the electronics, I moved away from loose jumper wires and instead soldered the core components onto perfboard. The system uses an ESP32-C3 microcontroller, HC-SR04 ultrasonic sensor, TB6612FNG motor driver, two N20 geared motors, and a split-voltage power system using a buck converter. This allowed the motors to receive higher voltage while the control electronics remained safely regulated. I programmed the robot to continuously measure distance ahead. When an obstacle comes within approximately 15 cm, the robot brakes, reverses, and chooses a left or right escape direction using a simple randomized parity check. This helps prevent it from repeatedly getting trapped in corners. The project gave me hands-on experience combining mechanical design, electronics, embedded control, and product-style packaging into a single compact system. **Skills developed:** Fusion 360, snap-fit design, 3D printing, soldering, ESP32 programming, sensor integration, motor control, power management, and system integration.
read the full paper ↗