Engineering & Product Development
Prosthetic Arm
May – July 2026
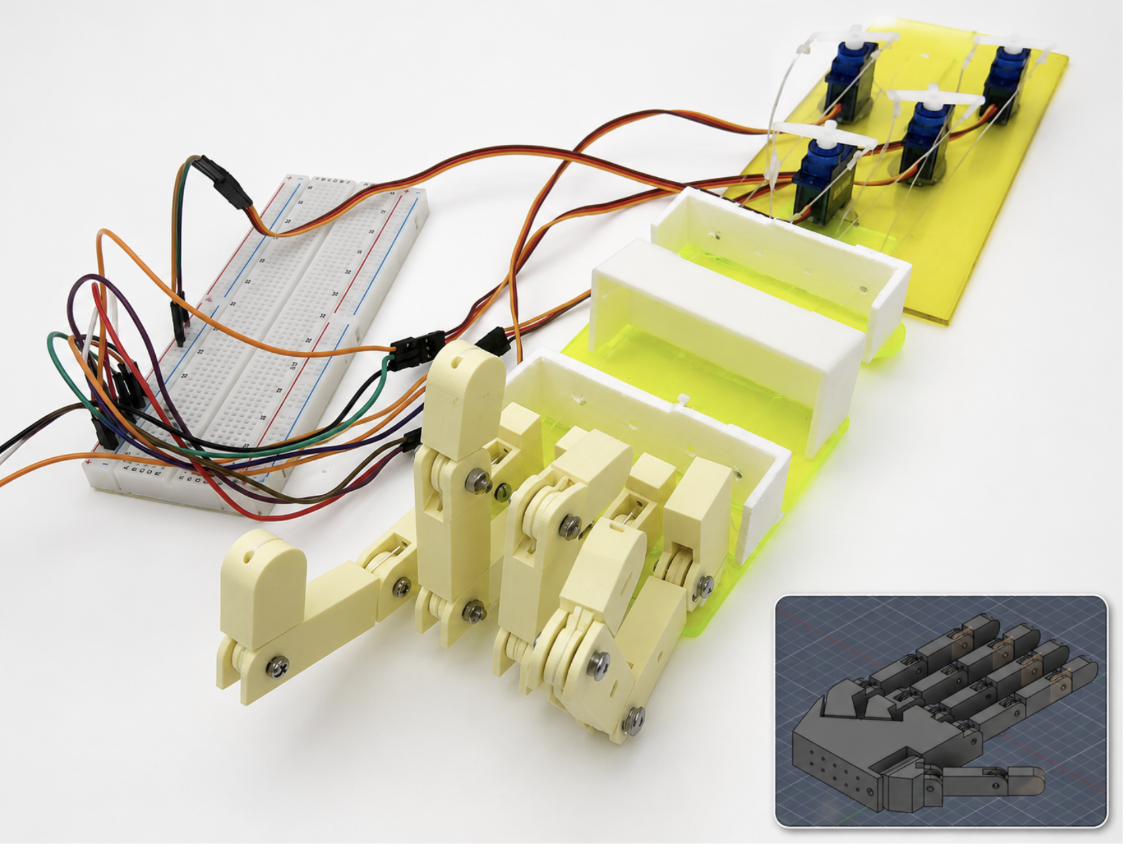
3D-printed tendon-driven prosthetic hand with servo actuation
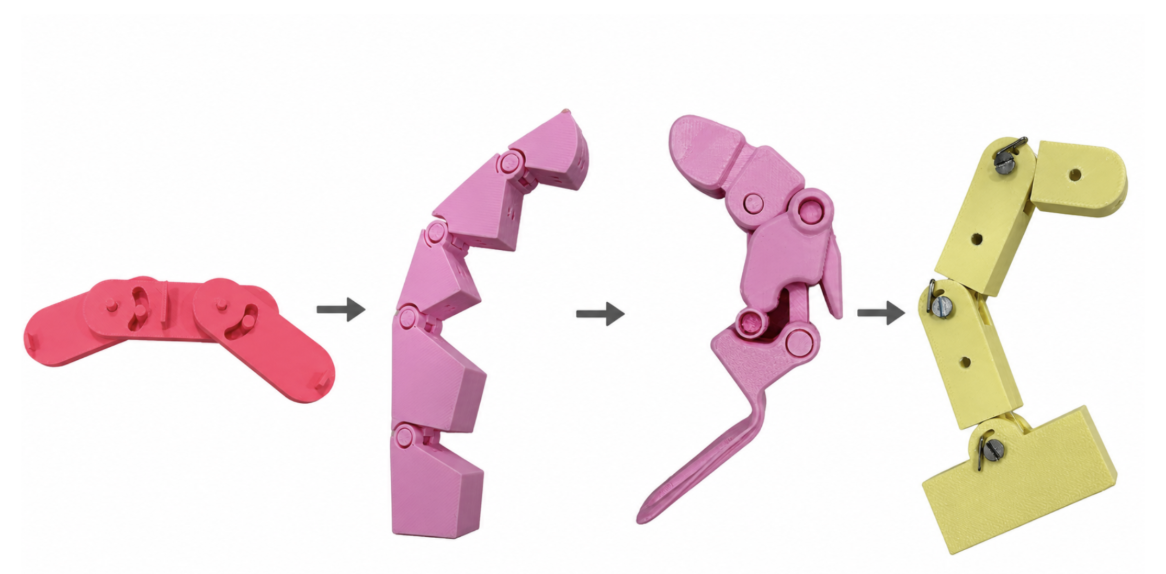
During my internship at MakerWorks Lab in Mumbai, I worked with engineer and mentor Abhay Waghmare, an IIT alumnus, to design and prototype a fully 3D-printed prosthetic hand inspired by the tendon-driven mechanics of the human hand. Before beginning in CAD, I studied finger anatomy and existing prosthetic mechanisms to understand how natural motion is created. One key insight was that finger movement is largely driven by tendons pulling from outside the fingers themselves, which led me to use nylon fishing line as artificial tendons and servo motors as the actuators. Rather than attempting a complete hand immediately, I followed an iterative design process beginning with a single finger. Early prototypes tested different joint geometries, hinge placements, segment lengths, and tendon-routing paths. Some versions had limited movement or jammed during flexion, while others bent in ways that did not resemble a natural finger. Each iteration helped refine the geometry until the finger could curl more smoothly and consistently. Once the finger mechanism worked, I connected it to nylon tendons and began testing servo-driven motion. This exposed a new challenge: even small amounts of slack in the tendons caused inconsistent movement. I then scaled the system to multiple fingers mounted on an acrylic test plate, allowing each finger to be actuated independently through an Arduino-controlled servo. The final stage involved designing a printable palm that could position all five fingers while accommodating tendon routing and future electronics. The current prototype demonstrates coordinated tendon-driven finger motion and serves as the foundation for future improvements in grip strength, thumb articulation, and overall dexterity. **Skills developed:** CAD, biomimetic design, rapid prototyping, 3D printing, Arduino, servo control, electronics integration, iterative testing, and mechanical system design.
read the full paper ↗